● Logistics · drones & docks
Stock that matches the aisle.Drone counts, dock scans, and conveyor totals.
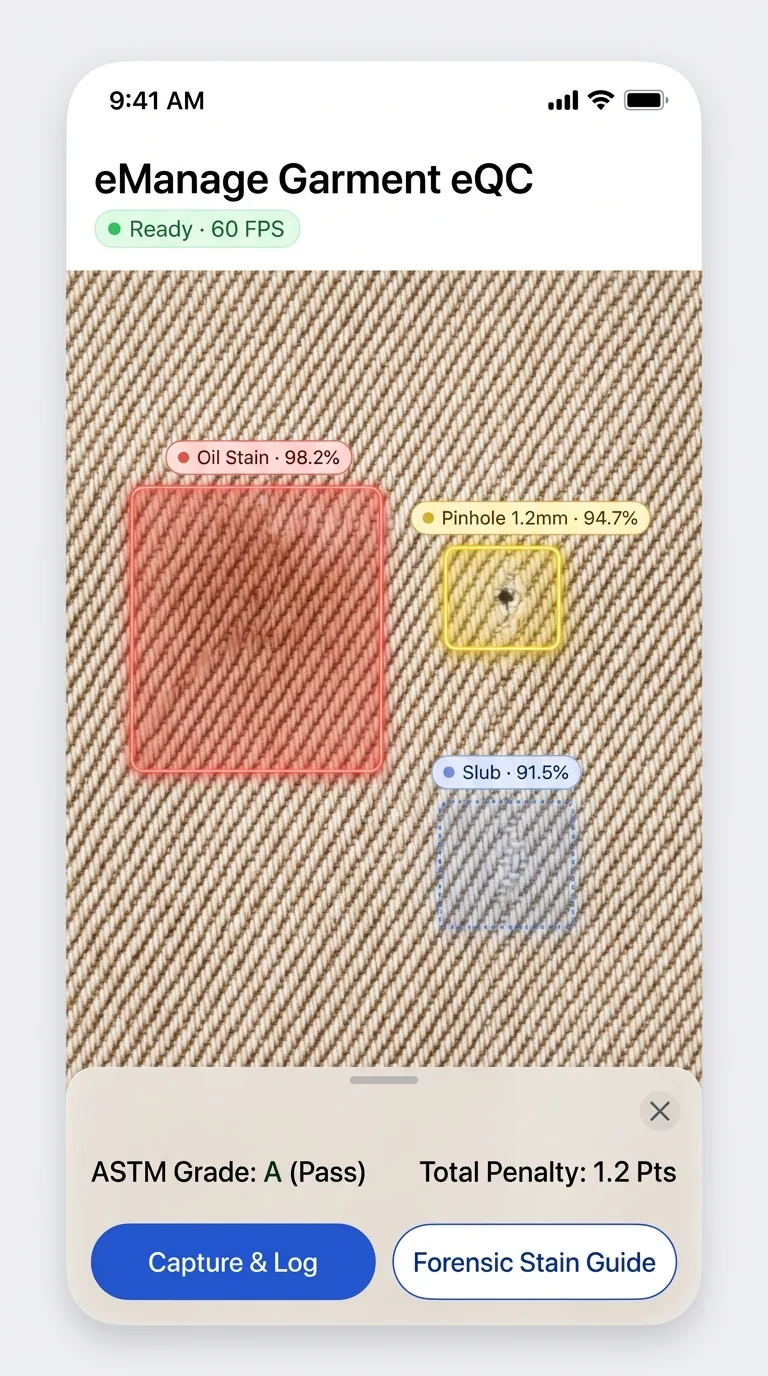
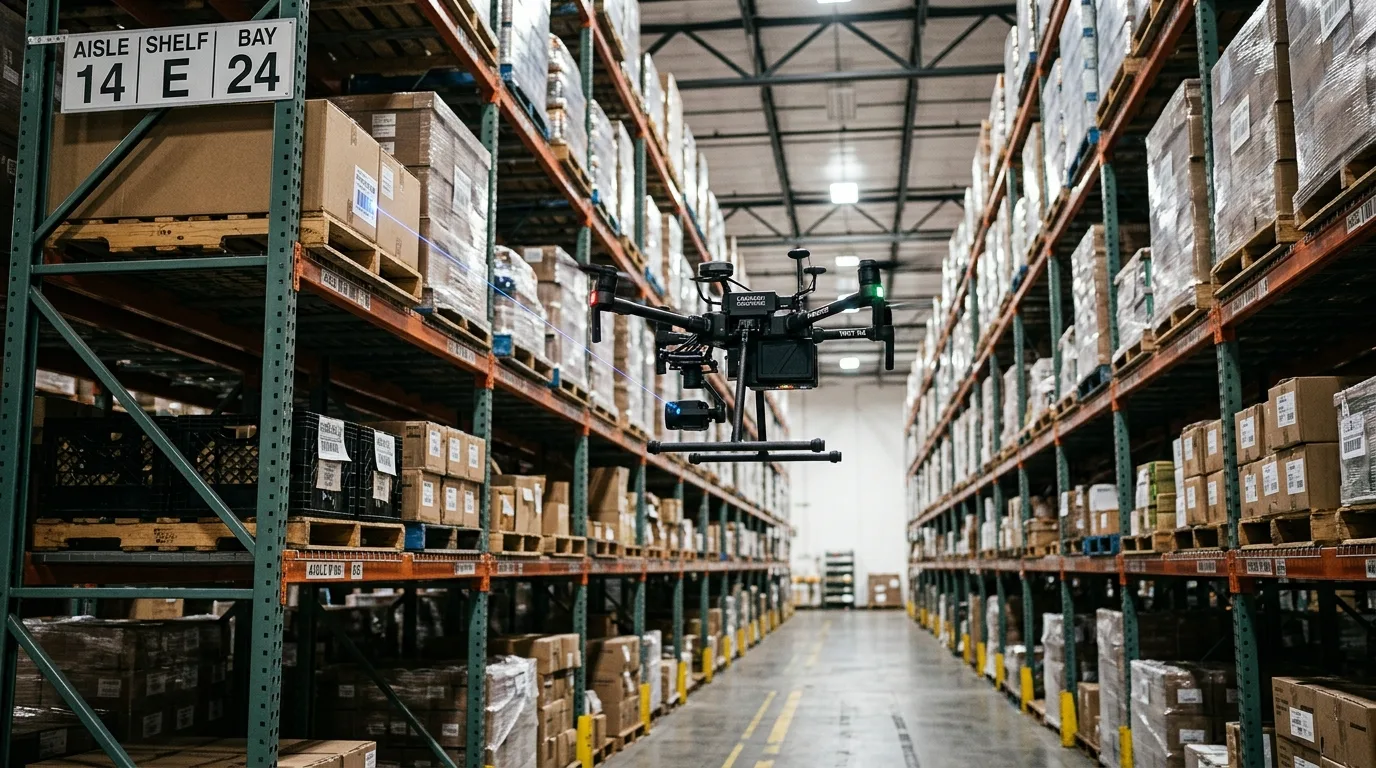
eManage warehouse vision uses autonomous indoor drones (900+ bins/hour), conveyor camera tunnels, and CNN/OCR reconstruction of damaged barcodes to audit physical stock against ERP rack masters without scissor lifts.
Count
900+ / hr
15× vs scissor lift
Codes
Torn OK
Super-res OCR
Zones
Dock → gate
Six watched areas
Proof
Pack video
Dispute pack
Phantom stock
The system said full. The aisle was empty.
Global inventory distortion is a scanning, placement, and barcode problem. Annual counts are too late. Cherry pickers are a fall hazard.
40–60/hr
Manual bins
Two people, a lift, an aisle closed, a minute a location.
Torn labels
Laser gives up
Crease, wrap glare, or a missing digit and the SKU is ‘unknown’.
Disputes
He-said packing
No video of the table when the carton left short.
Lift vs drone
| Capability | Scissor / cherry picker | eManage drone + vision |
|---|---|---|
| Rate | 40–60 bins/hour | 900+ bins/hour |
| People | Two + closed aisle | Unmanned, LiDAR avoid |
| Labels | Laser fail on damage | Reconstruct + OCR + reprint |
| When | Daylight count | After shift or live |
Demo clips
Watch it run
Packing count
Every garment counted as it goes into the carton.
Unloading count
Castings counted one by one as they come off the truck and into stock.
Fabric roll count
Each roll counted off the truck and again as it lands on the stock pile.
From the floor
What the camera actually sees
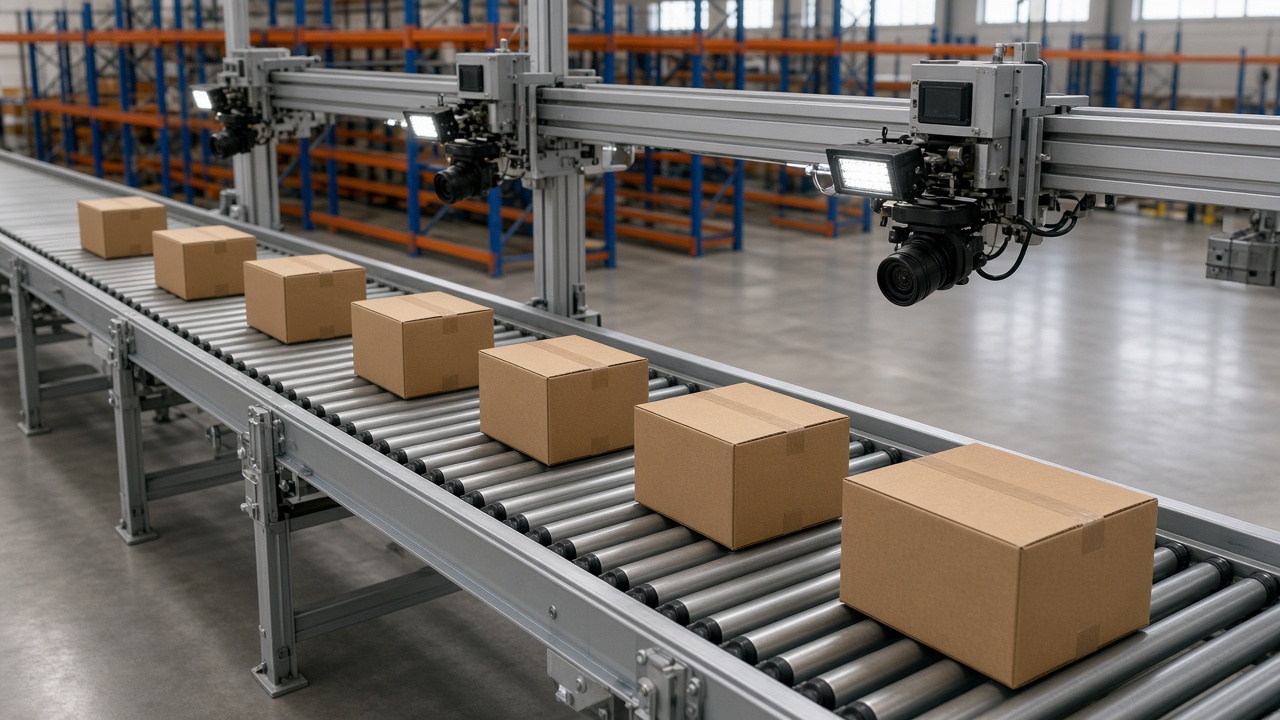
Conveyor inventory count
Bounding boxes on each carton — class, index, and a running shift total.
Dock-to-dispatch topology
Receiving, high-bay buffers, and dispatch bays on one vision map.
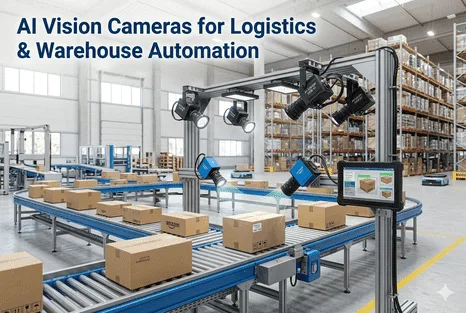
Conveyor tunnel
Global-shutter cameras reading 1D/2D codes and cubing to ~2.5–3 m/s.
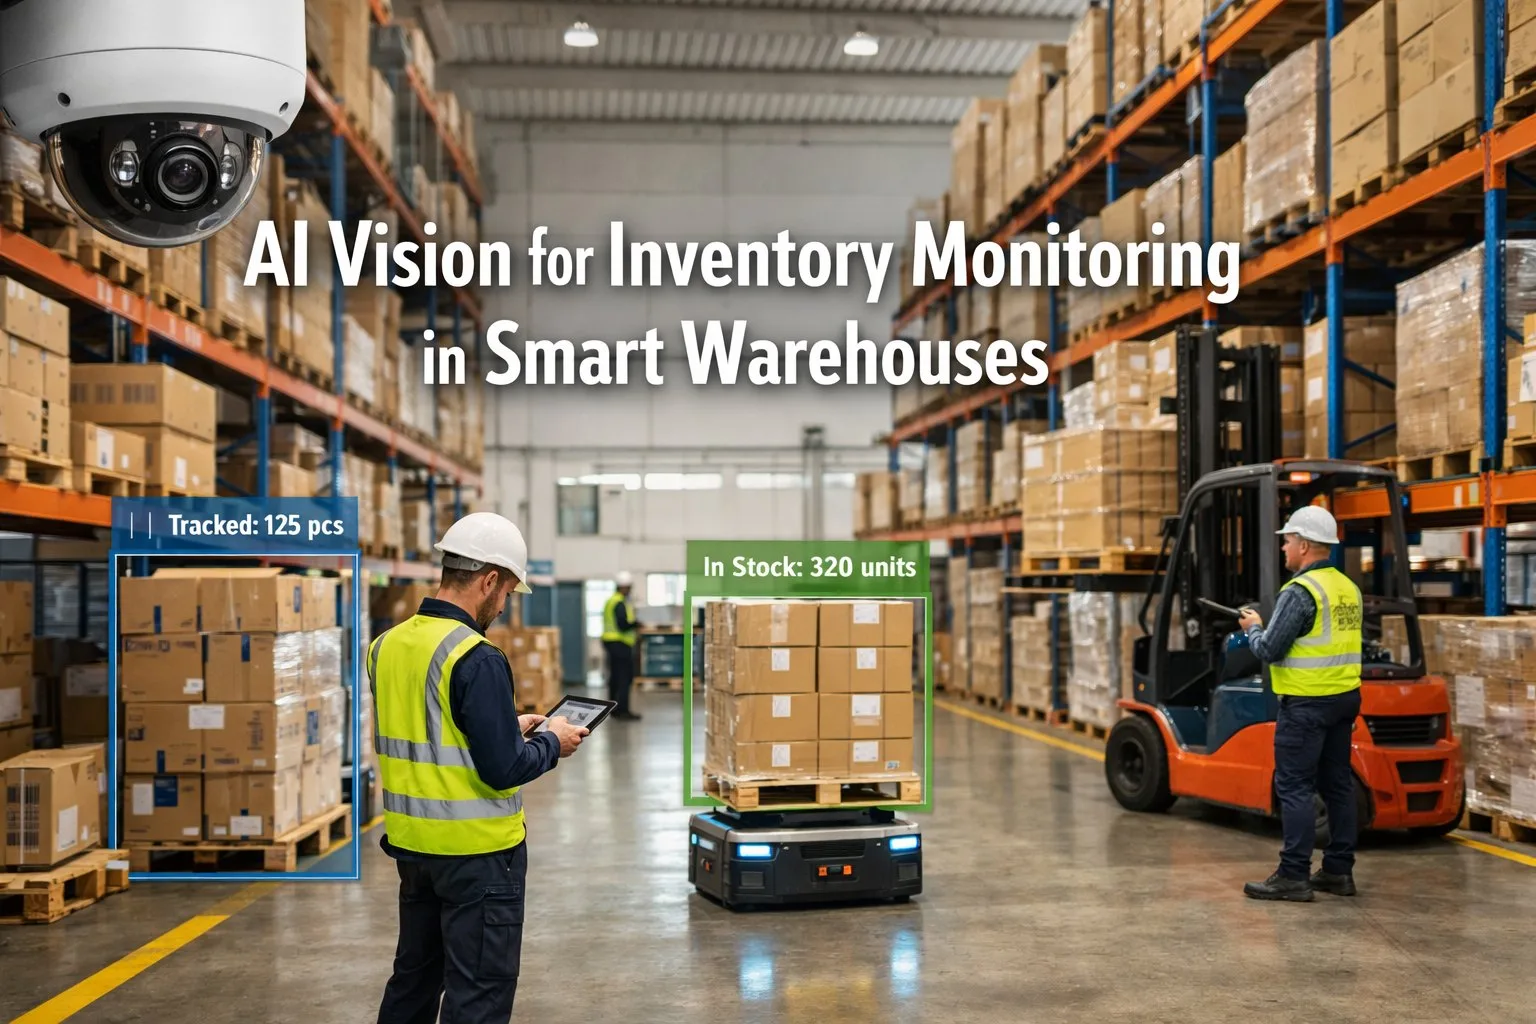
Rack occupancy
Slot telemetry against the eManage rack master — vacant, overhang, double-deep.
Facility coverage
Six watched zones
Cameras sit on the flow, not on a weekend count. Each zone writes a different ERP object.
01
Receiving dock
Overhead cameras match pallet count to the ASN, flag crushed cartons, timestamp the GRN.
02
High-bay / rack master
Drones and forklift stereo: vacant slots, overhang, double-deep errors, capacity heatmaps.
03
Dimensioning tunnels
Six-sided scan: barcodes, L×W×H cube, divert shoe for the sorter.
04
Pick & pack table
Top-down check of SKU, count, and inserts before the carton is sealed.
05
Staging / AGV
Floor-grid occupancy. Pallets past staging TTL get an AGV retrieve, not a hunt.
06
Dispatch audit
Dock video and plate read attach to the challan and e-way bill.
How it works
Four moves.
One write-back.
01
Fly the aisle
LiDAR SLAM drones after hours or in live aisles. Multi-level barcodes, crushed cartons flagged.
02
Tunnel the sorter
Global-shutter cameras on conveyors to 3 m/s: 1D/2D codes, cube, crush, weight check.
03
Rebuild the code
CNN enhancement plus OCR of human-readable backup; reprint to a nearby wireless printer.
04
Reconcile the rack
Physical vs ERP in seconds. Pack-table video attaches to the dispatch order.
Overhead tunnel · class + count per carton · write-back to rack master
Rate
Bins per hour, same aisle
Scissor lift
50
Two people. Closed aisle. Fall hazard.
● eManage drone
900+
LiDAR SLAM. Night shift. 15× the lift.
Rack master is the source of truth again
Bin allocations, GRN, and dispatch orders update from what the camera saw — including eManage warehouse app workflows.
- No camera rip-and-replace: ONVIF/RTSP plus edge Jetson/TensorRT
- Works beside existing WMS; eManage remains the mill ledger
- Pack-table video ends ‘short shipment’ arguments
Questions plants actually ask
Manual high-bay counts need two people and ~1 minute a bin (40–60/hour) with fall risk. Drones scan 900+ locations/hour with LiDAR obstacle avoidance.
CNN reconstruction plus transformer OCR reads partial symbology and human-readable text, then can fire a reprint.
Overhead tunnels with global shutter capture 5- or 6-sided views to 3 m/s, cube the carton, and check weight vs the order.
Usually no. We hang off ONVIF/RTSP you already have and add edge inference boxes.
Next